BRAVE BORDERER
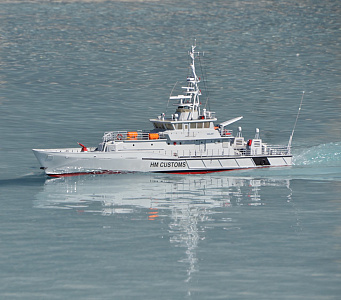
Whilst waiting for the new motors and ESCs, reviewed videos of the vessel under power and noted that as the speed increases, the bow lifts towards a plane. However, as she gathers speed the transom flaps become effective, forcing the bow down in a cloud of spray. At this point the plane has been lost and the model becomes almost uncontrollable.
Decided to temporarily ballast the hull to simulate the new motors and ESCs, then try to establish the optimum flap angle using just the centre propeller and shaft. This is the original 2838 brushless motor installation with a 30 mm propeller. With this simulated drivetrain it would also be an opportunity to determine the best battery locations for both 2 and 3S Li-Po batteries.
Made up an angle template with a spirit level to get the correct deck inclination with the vessel floating at rest. From this located each type of battery statically - somewhere close to the mid-point of the hull. Which also seemed as good a place to start as any!
Somewhere in the research for this model found a reference to the transom flap angle. This was at a 2 degree -ve (pointing downwards) angle. installed the 2S battery and tried the model. The bow dug in at speed. Adjusted the flap to a straight and level position and tried again. The bow still wanted to dig in, but to a reduced extent. Readjusted the angle to 2 + ve and repeated. The bow now lifted so the forefoot just cleared the water and then remained in that position.
Replaced the 2S battery with the 3S. The extra power obviously increased speed and the bow lifted slightly further. The spray was deflected by the chine rails and a level plane established.
The conclusion is that the transom flap angle is critical to the correct planing of this model and that it should not be negative.
Until the new motors and ESCs are fitted will leave the transom flap and battery locations as is. Once these components are installed, intend to repeat the test. Am confident that with some fine tuning the model can be now made to plane properly at a scale speed.
Interesting to note that the model will just about plane with only one propeller operating – wonder what it will be like with all three?